Bluetooth-Controlled Robot Car
Arduino6–8 weeks
Project Overview
Build a four-wheel robot with smartphone direction and speed controls.
Objectives & Learning Outcomes
UART commands, motor driver PWM, safe stopping and battery supervision
Required Hardware
Arduino Nano, HC-05 module, L298N, geared motors, chassis, battery protection
Suggested Build Stages
- Review the components and create a low-voltage wiring plan.
- Assemble the prototype and test each sensor or module individually.
- Implement firmware, display or communications in small verified steps.
- Integrate the modules and document operating states and failures.
- Run validation tests and prepare demonstration documentation.
Testing & Validation
Verify turns, emergency stop, radio disconnect and motor temperature.
Suggested Deliverables
Working demonstration, wiring diagram, commented firmware, test observations, component list, project report outline and presentation outline.
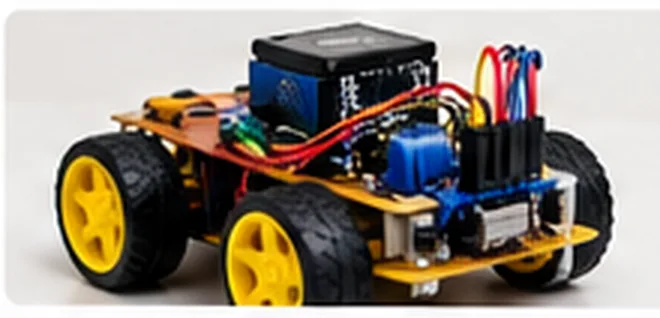
Educational project concept. Verify circuit values, actual component compatibility and safe operating limits before assembly. Illustrations are representative, not exact build photographs.
Project CodeTCS-MCU-104
Duration6–8 weeks
ComponentsArduino Nano, HC-05 module, L298N, geared motors, chassis, battery protection
Software / ToolsArduino IDE or PlatformIO as compatible with controller
DeliverablesPrototype, schematic/wiring diagram, source code, test report, PPT
Skills CoveredUART commands, motor driver PWM, safe stopping and battery supervision